Pixhawk
A flight-controller hardware family. Select the board and vehicle combination supported by your chosen autopilot firmware.
MAVLink operations. In the field.
The published Android ground-control application for ArduPilot and PX4 workflows via MAVLink.
A flight-controller hardware family. Select the board and vehicle combination supported by your chosen autopilot firmware.
The autopilot runs the vehicle. MAVLink carries the supported mission and telemetry messages between the vehicle and ground-control application.
The published Android ground-control pathway for mission planning, vehicle context and operational review. Exact board, firmware and vehicle setup must be qualified.
For DJI and Autel RC integration, explore VECTOR with NEXUS. Flight is the separate MAVLink application pathway.
Explore all platform families ↗Explore the published capability areas. Product configuration and deployment scope determine availability.
The Nexus brochure identifies Flight as the published Android GCS for ArduPilot/PX4 through MAVLink.
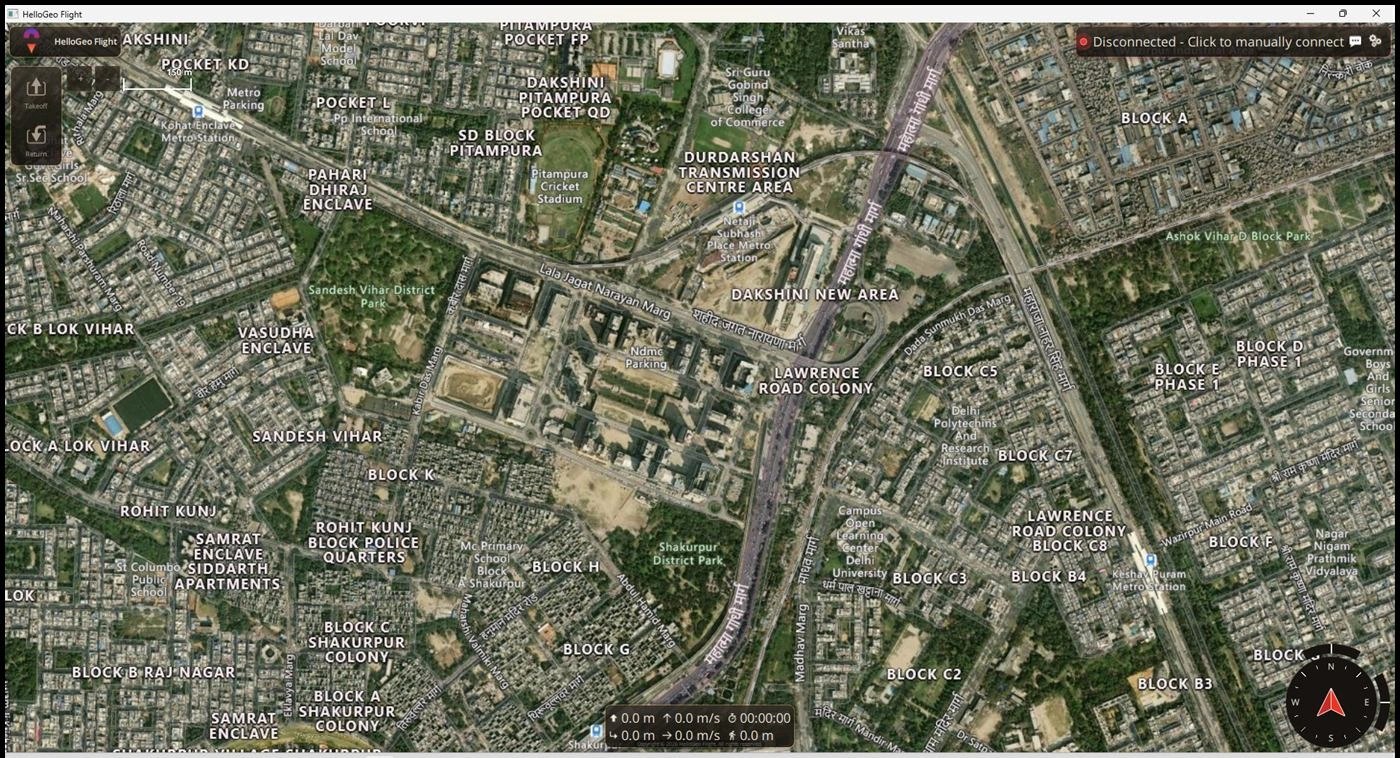
Bring mission planning and vehicle information to the field operator.
Define inputs, access requirements and acceptance criteria with the HelloGeo team before operational deployment.
Define inputs, access requirements and acceptance criteria with the HelloGeo team before operational deployment.
Define inputs, access requirements and acceptance criteria with the HelloGeo team before operational deployment.
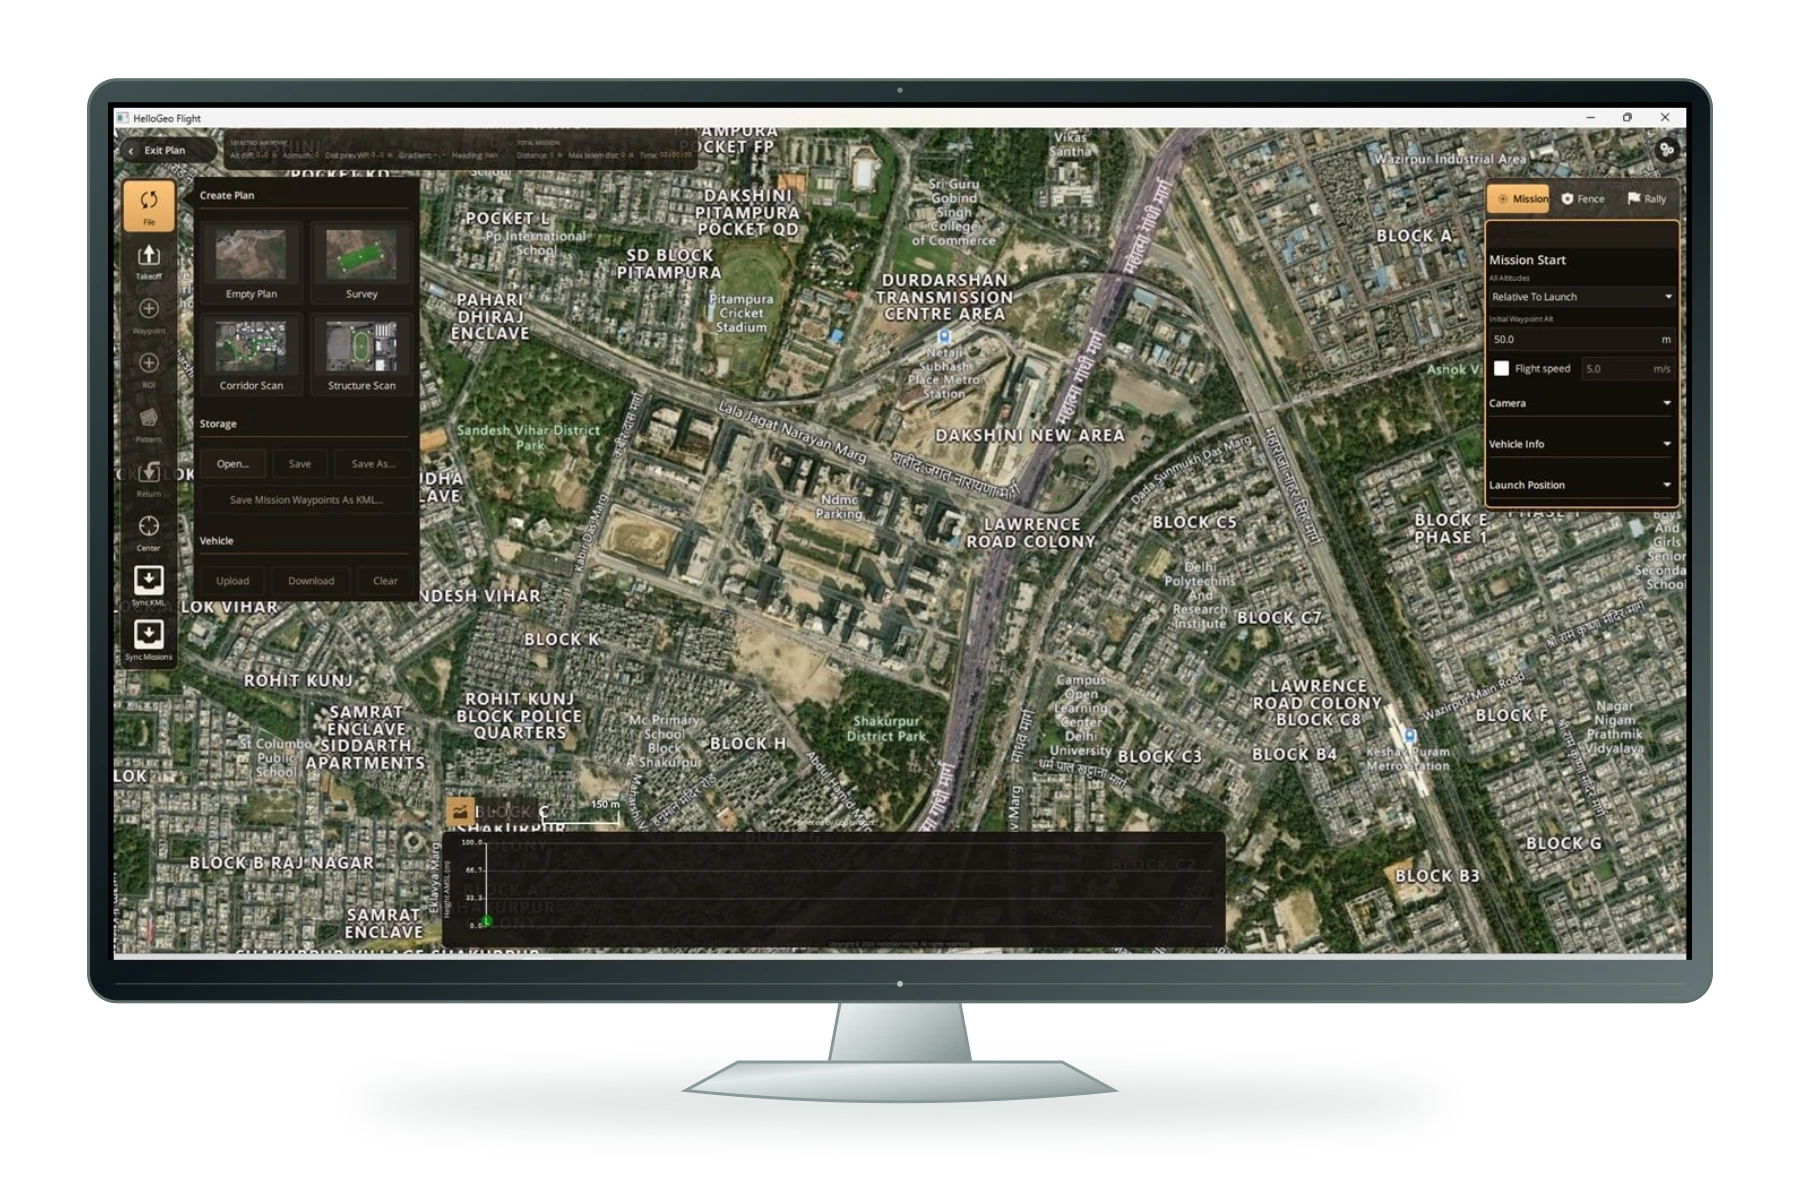
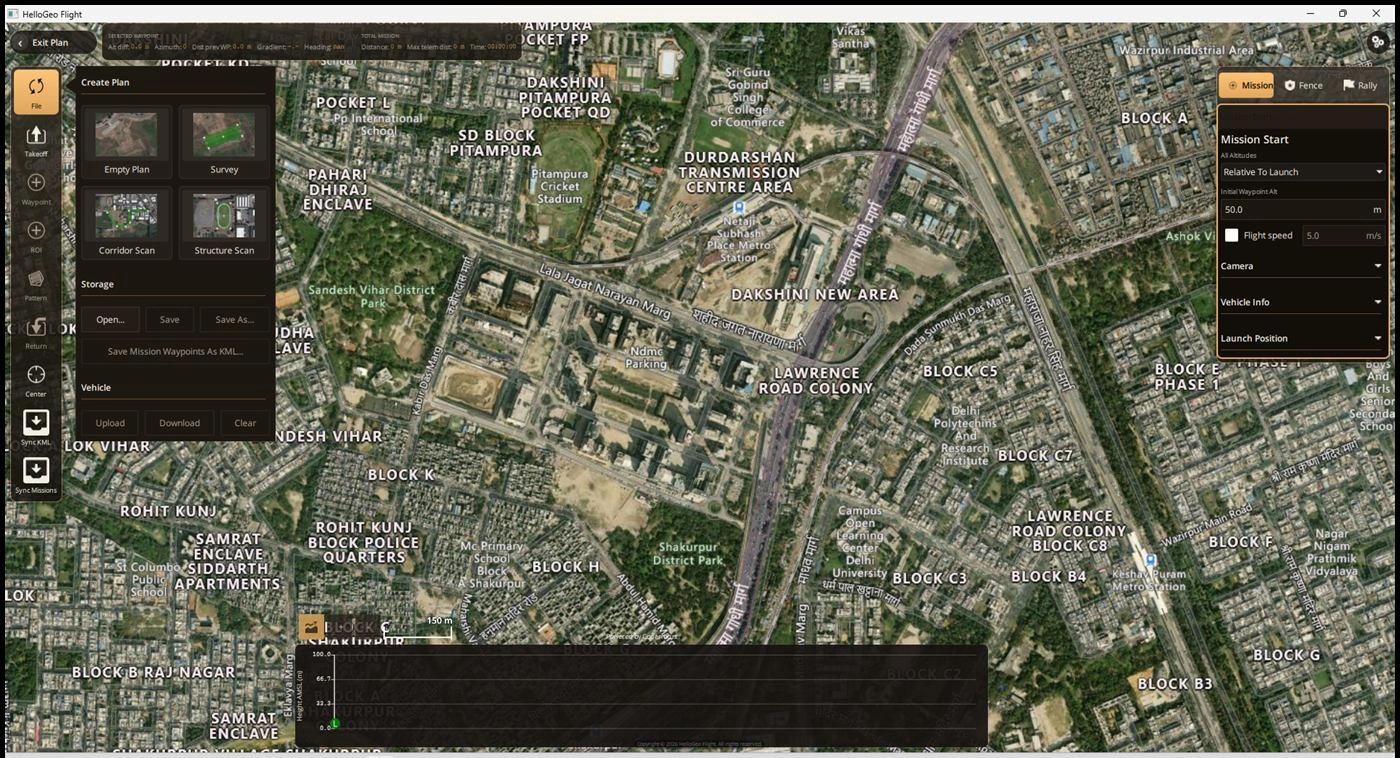
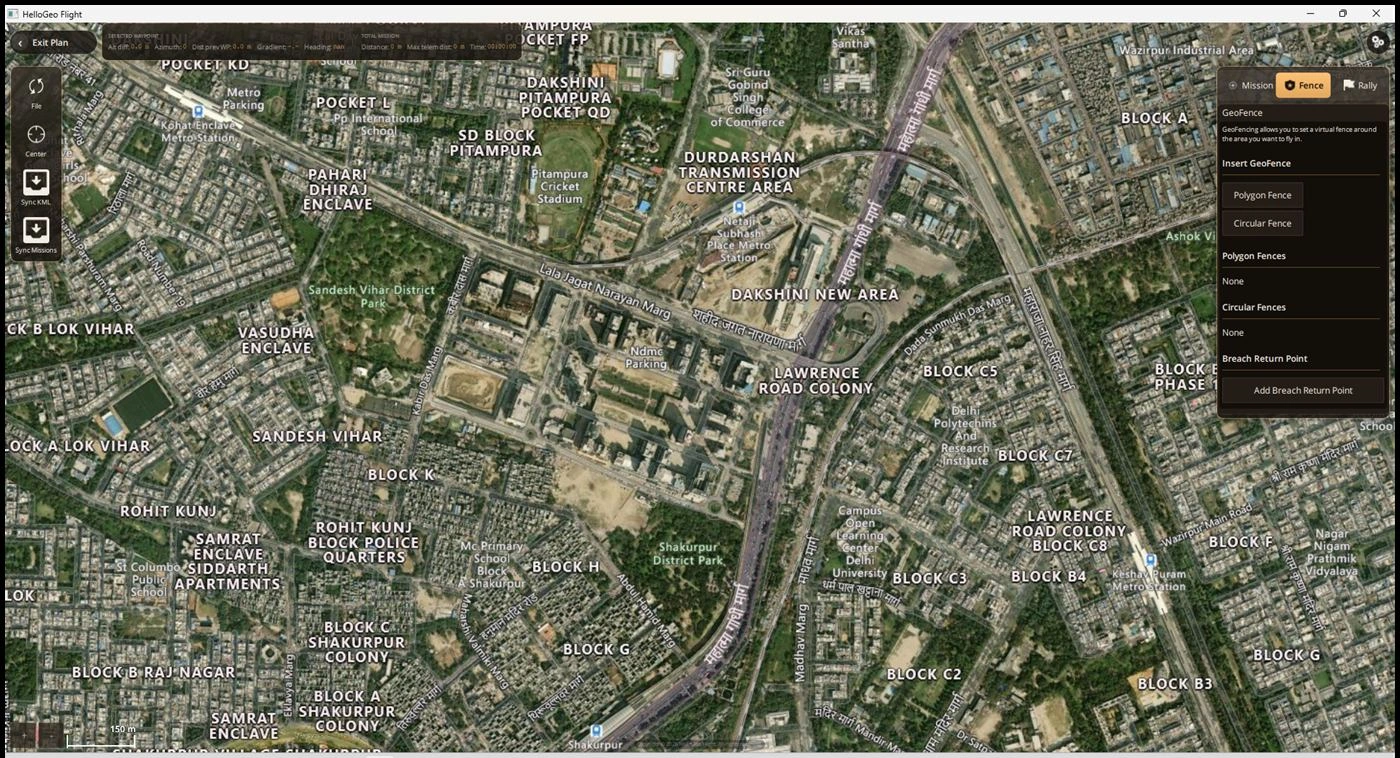
Explore mission patterns, map context, and geofence tools in Flight.
 Open full-size image
 Open full-size image
 Open full-size image
Your team knows the site. We know the spatial workflow. Together, we can define a practical way forward.