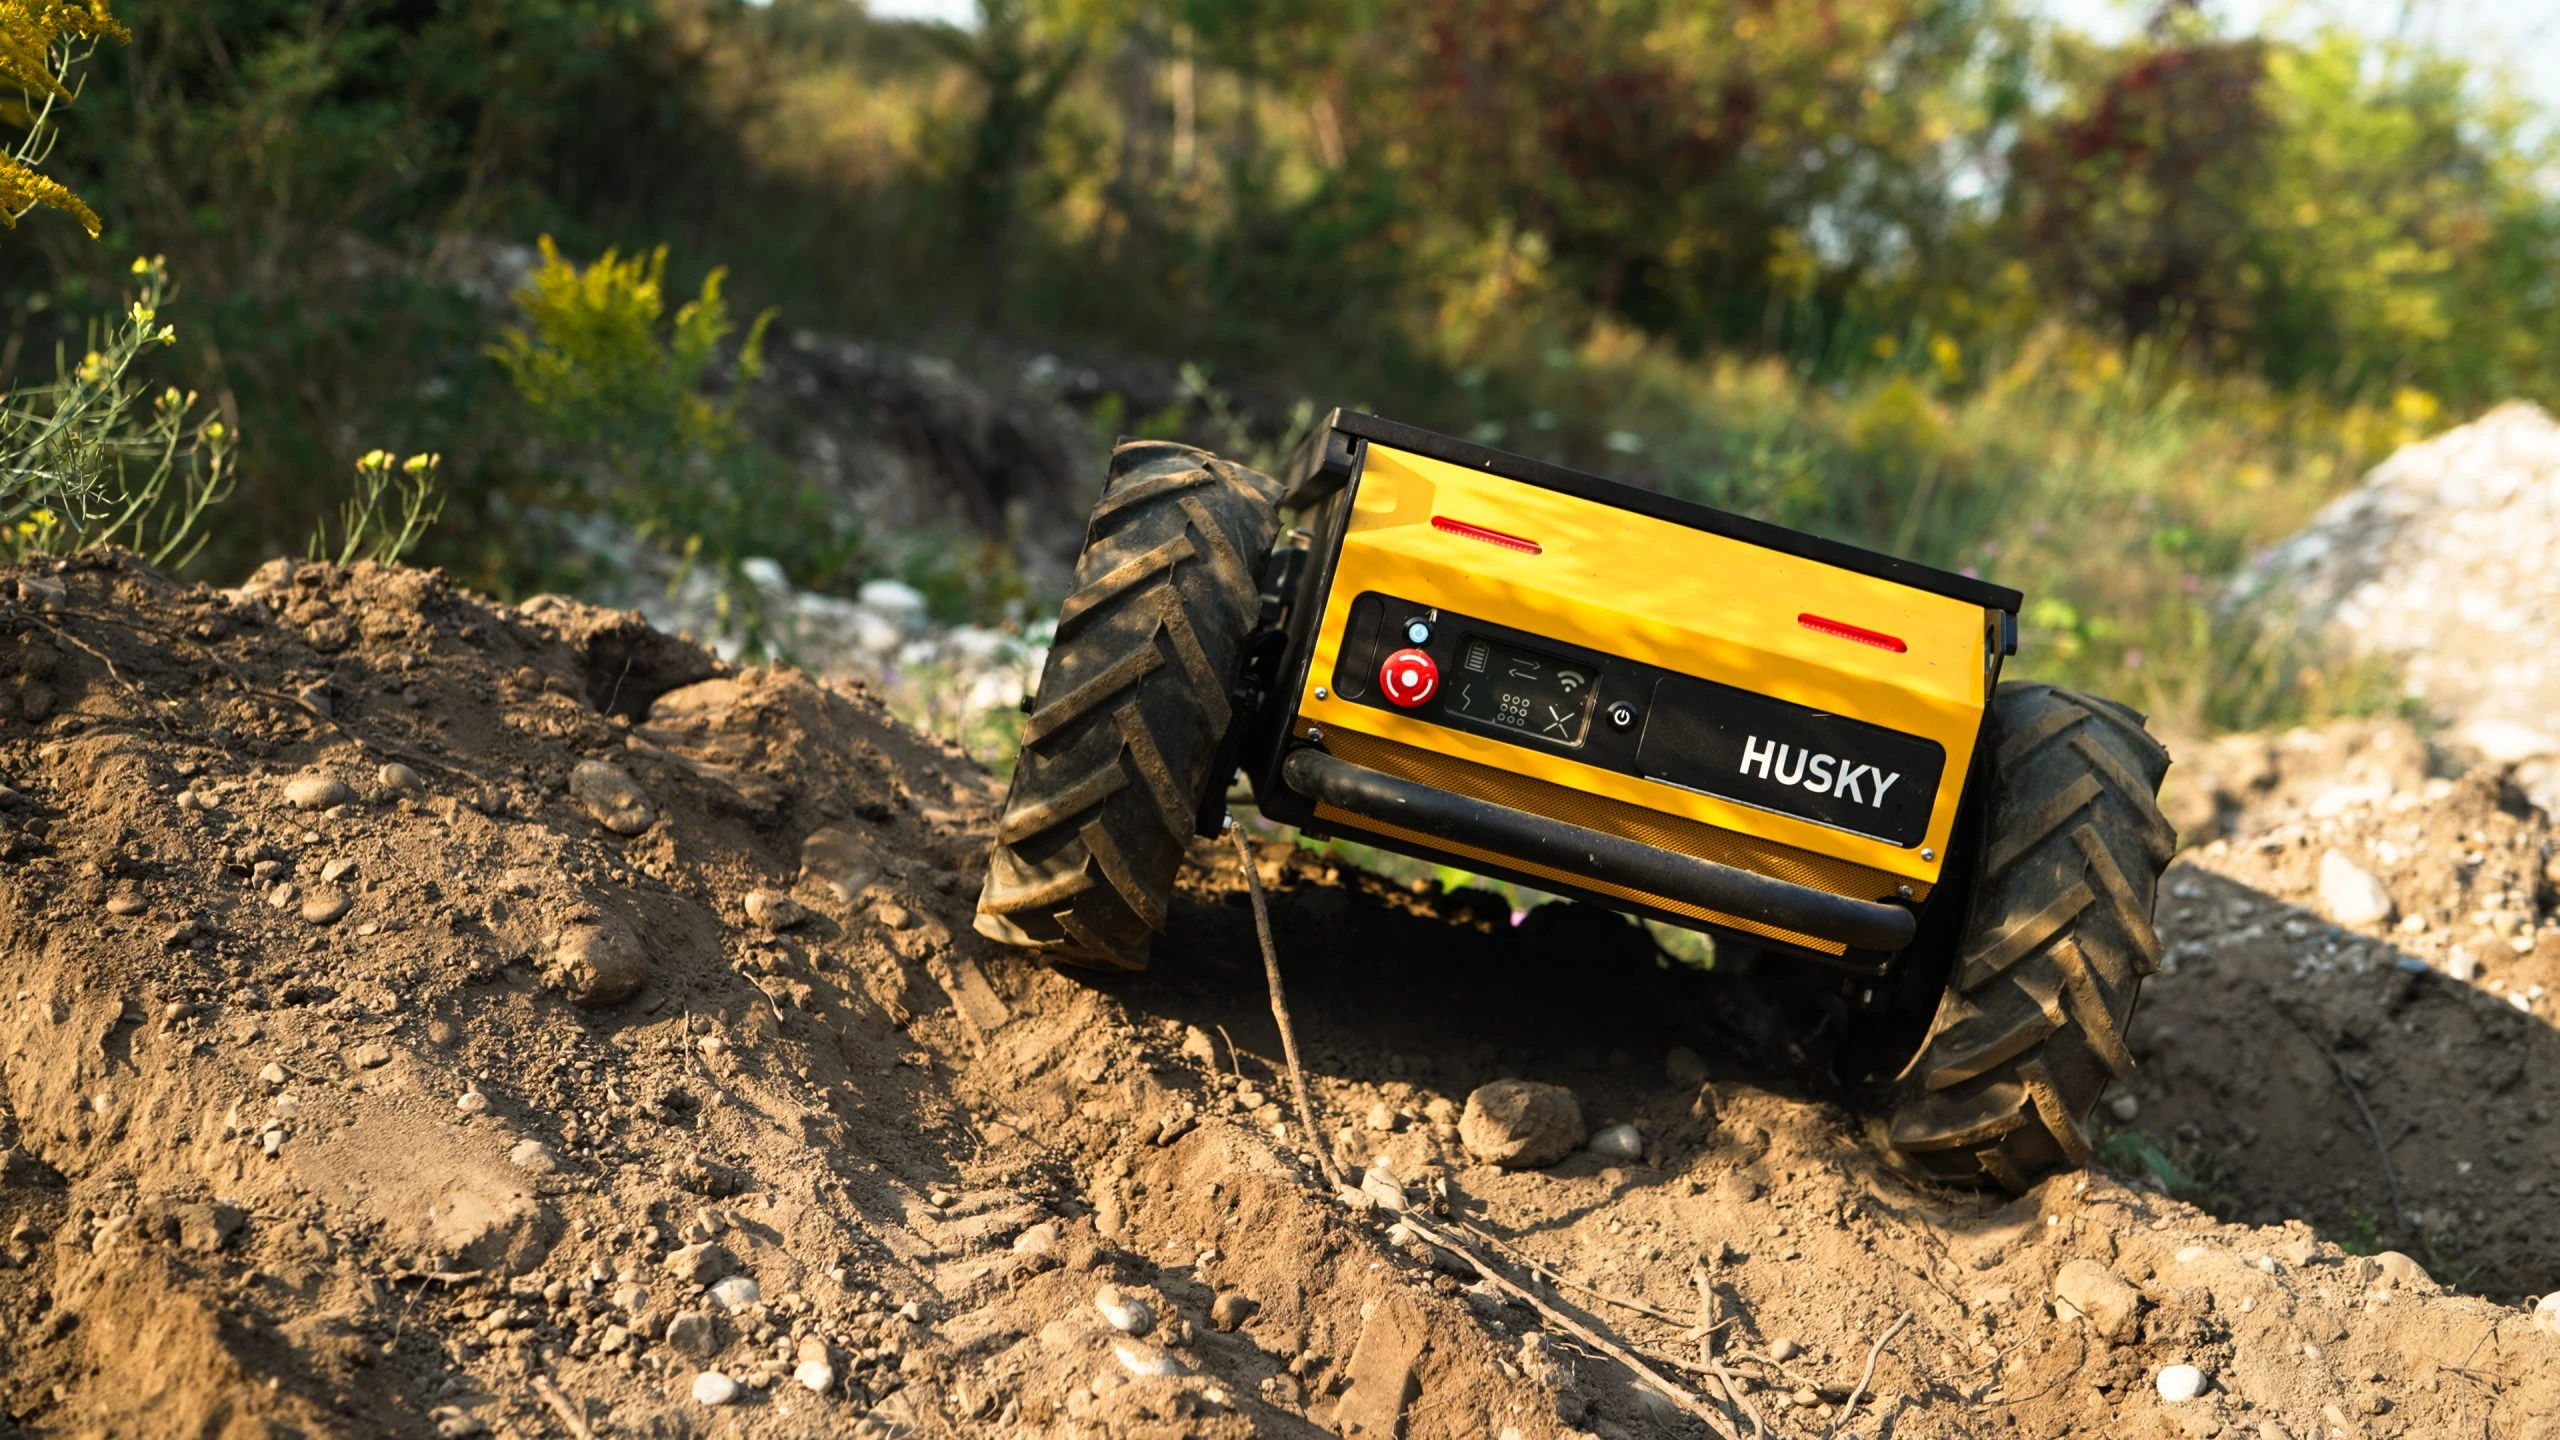
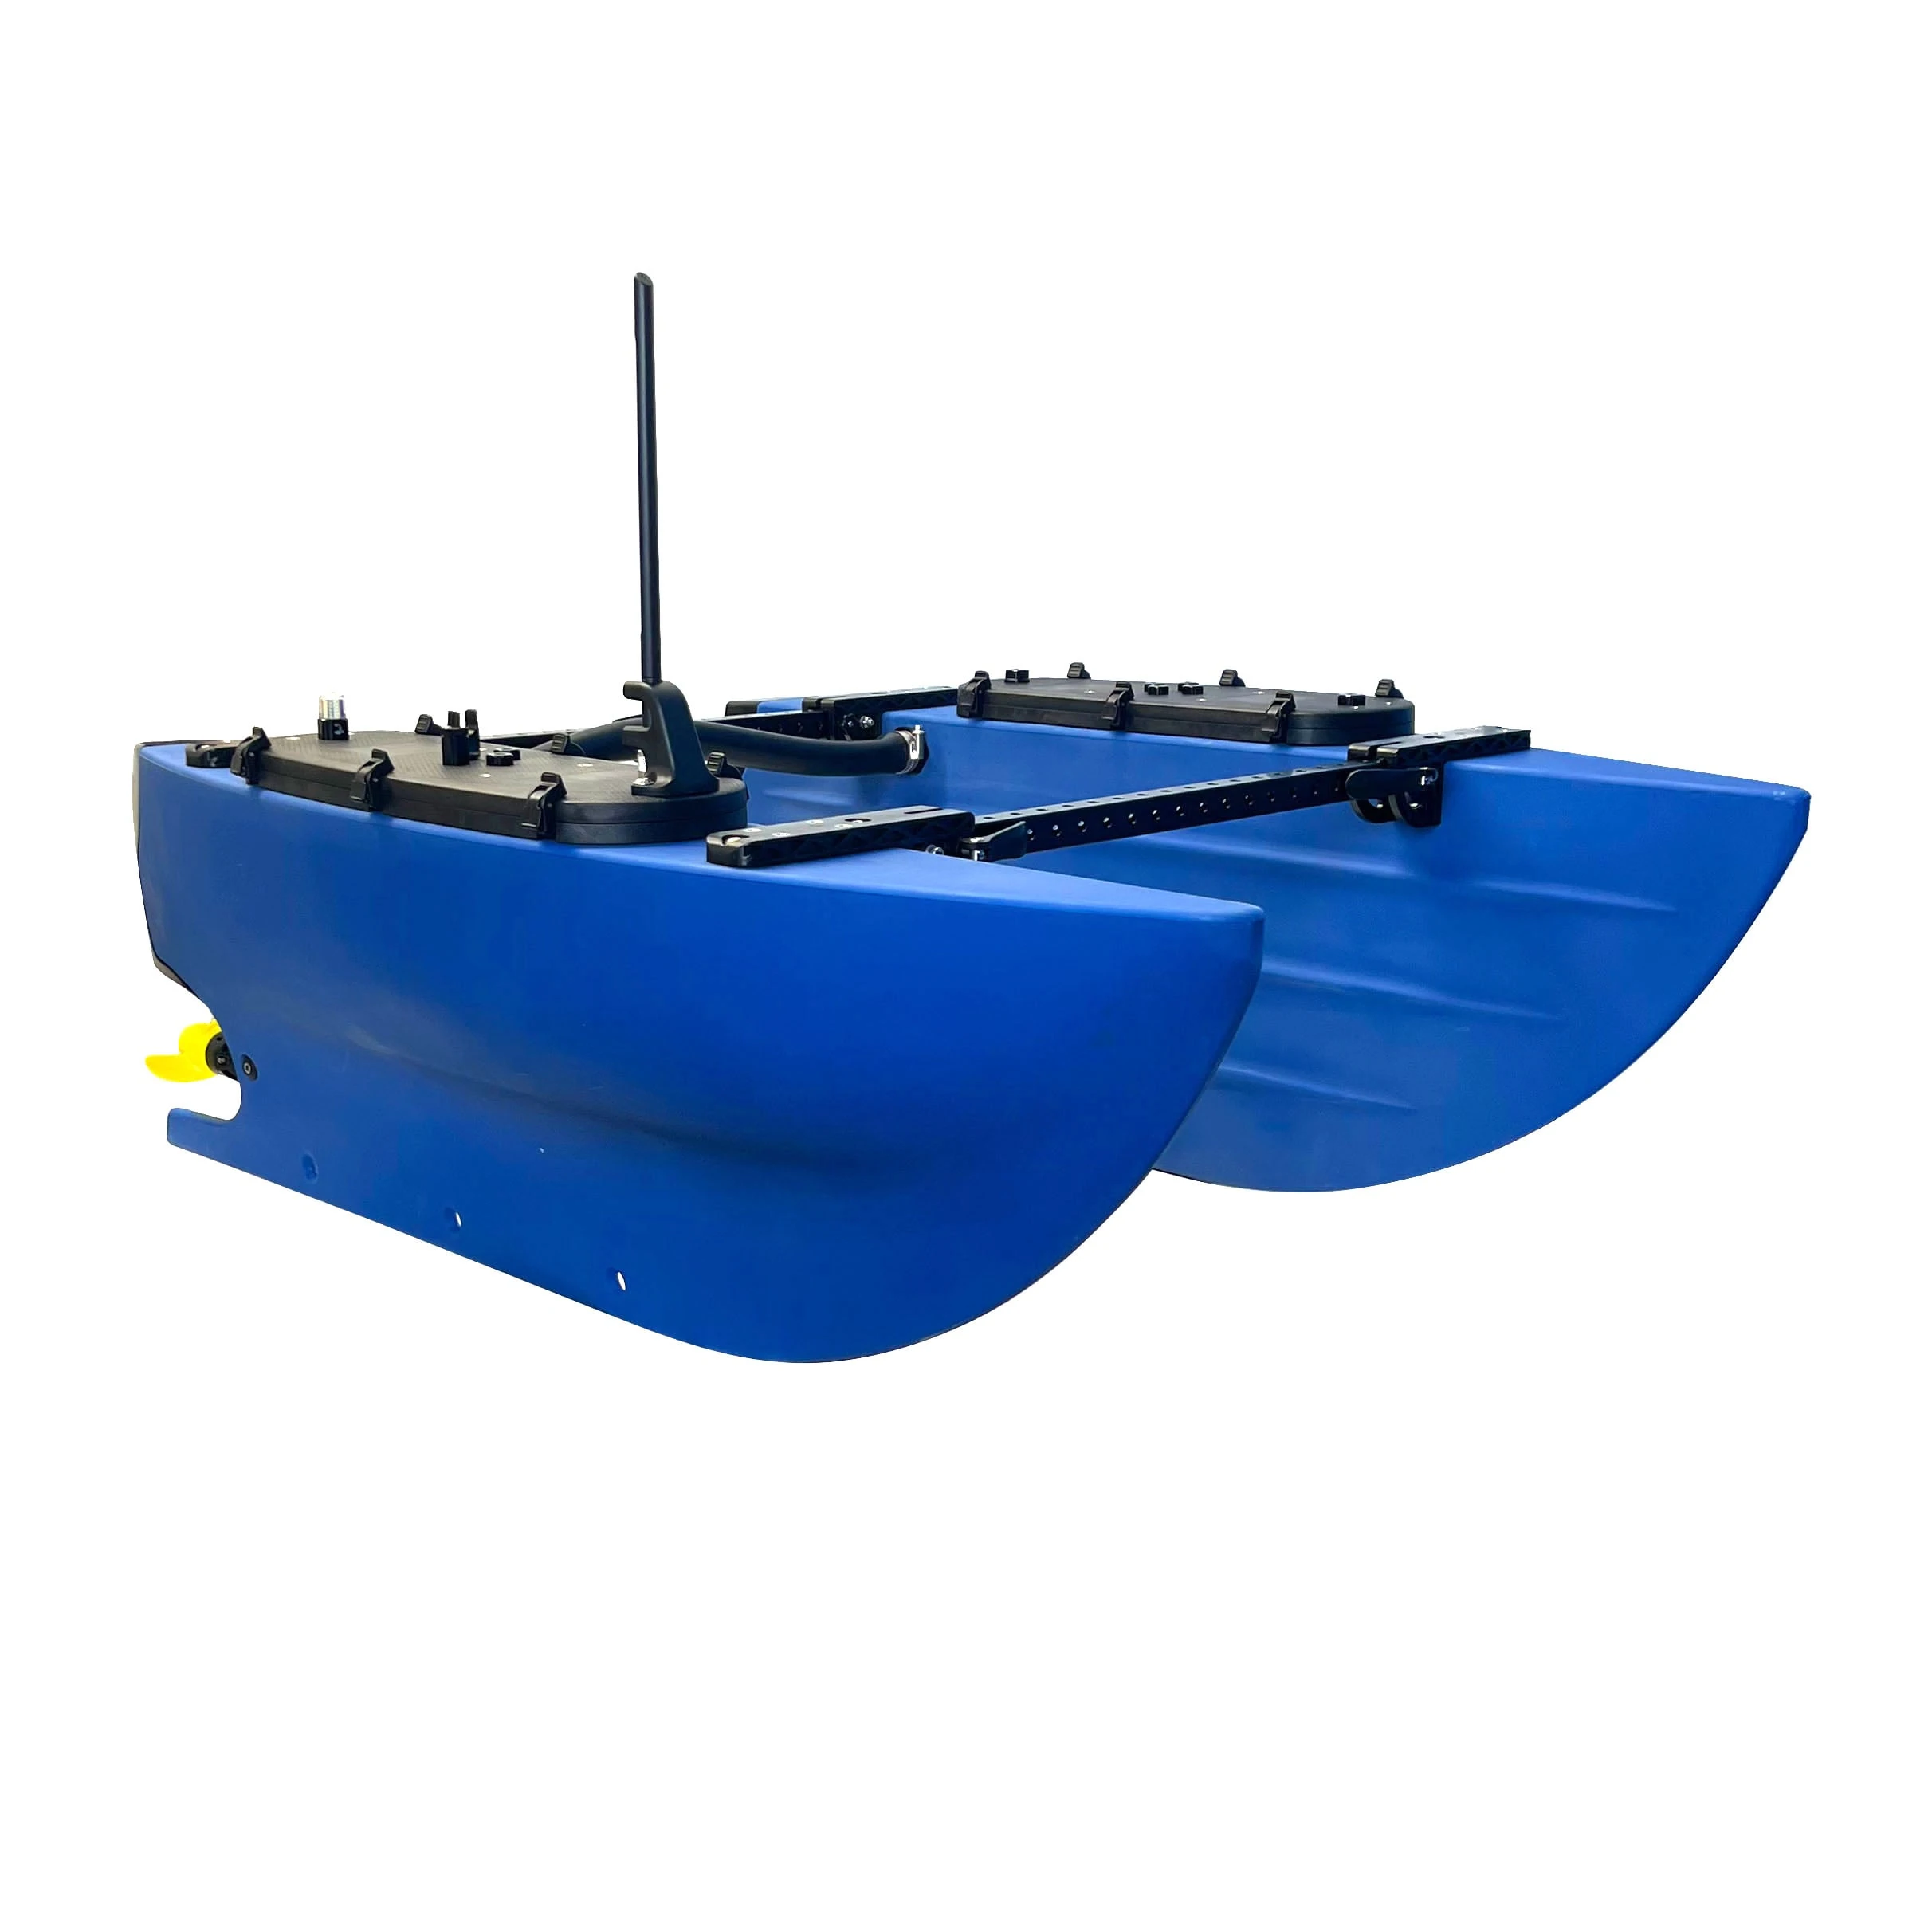
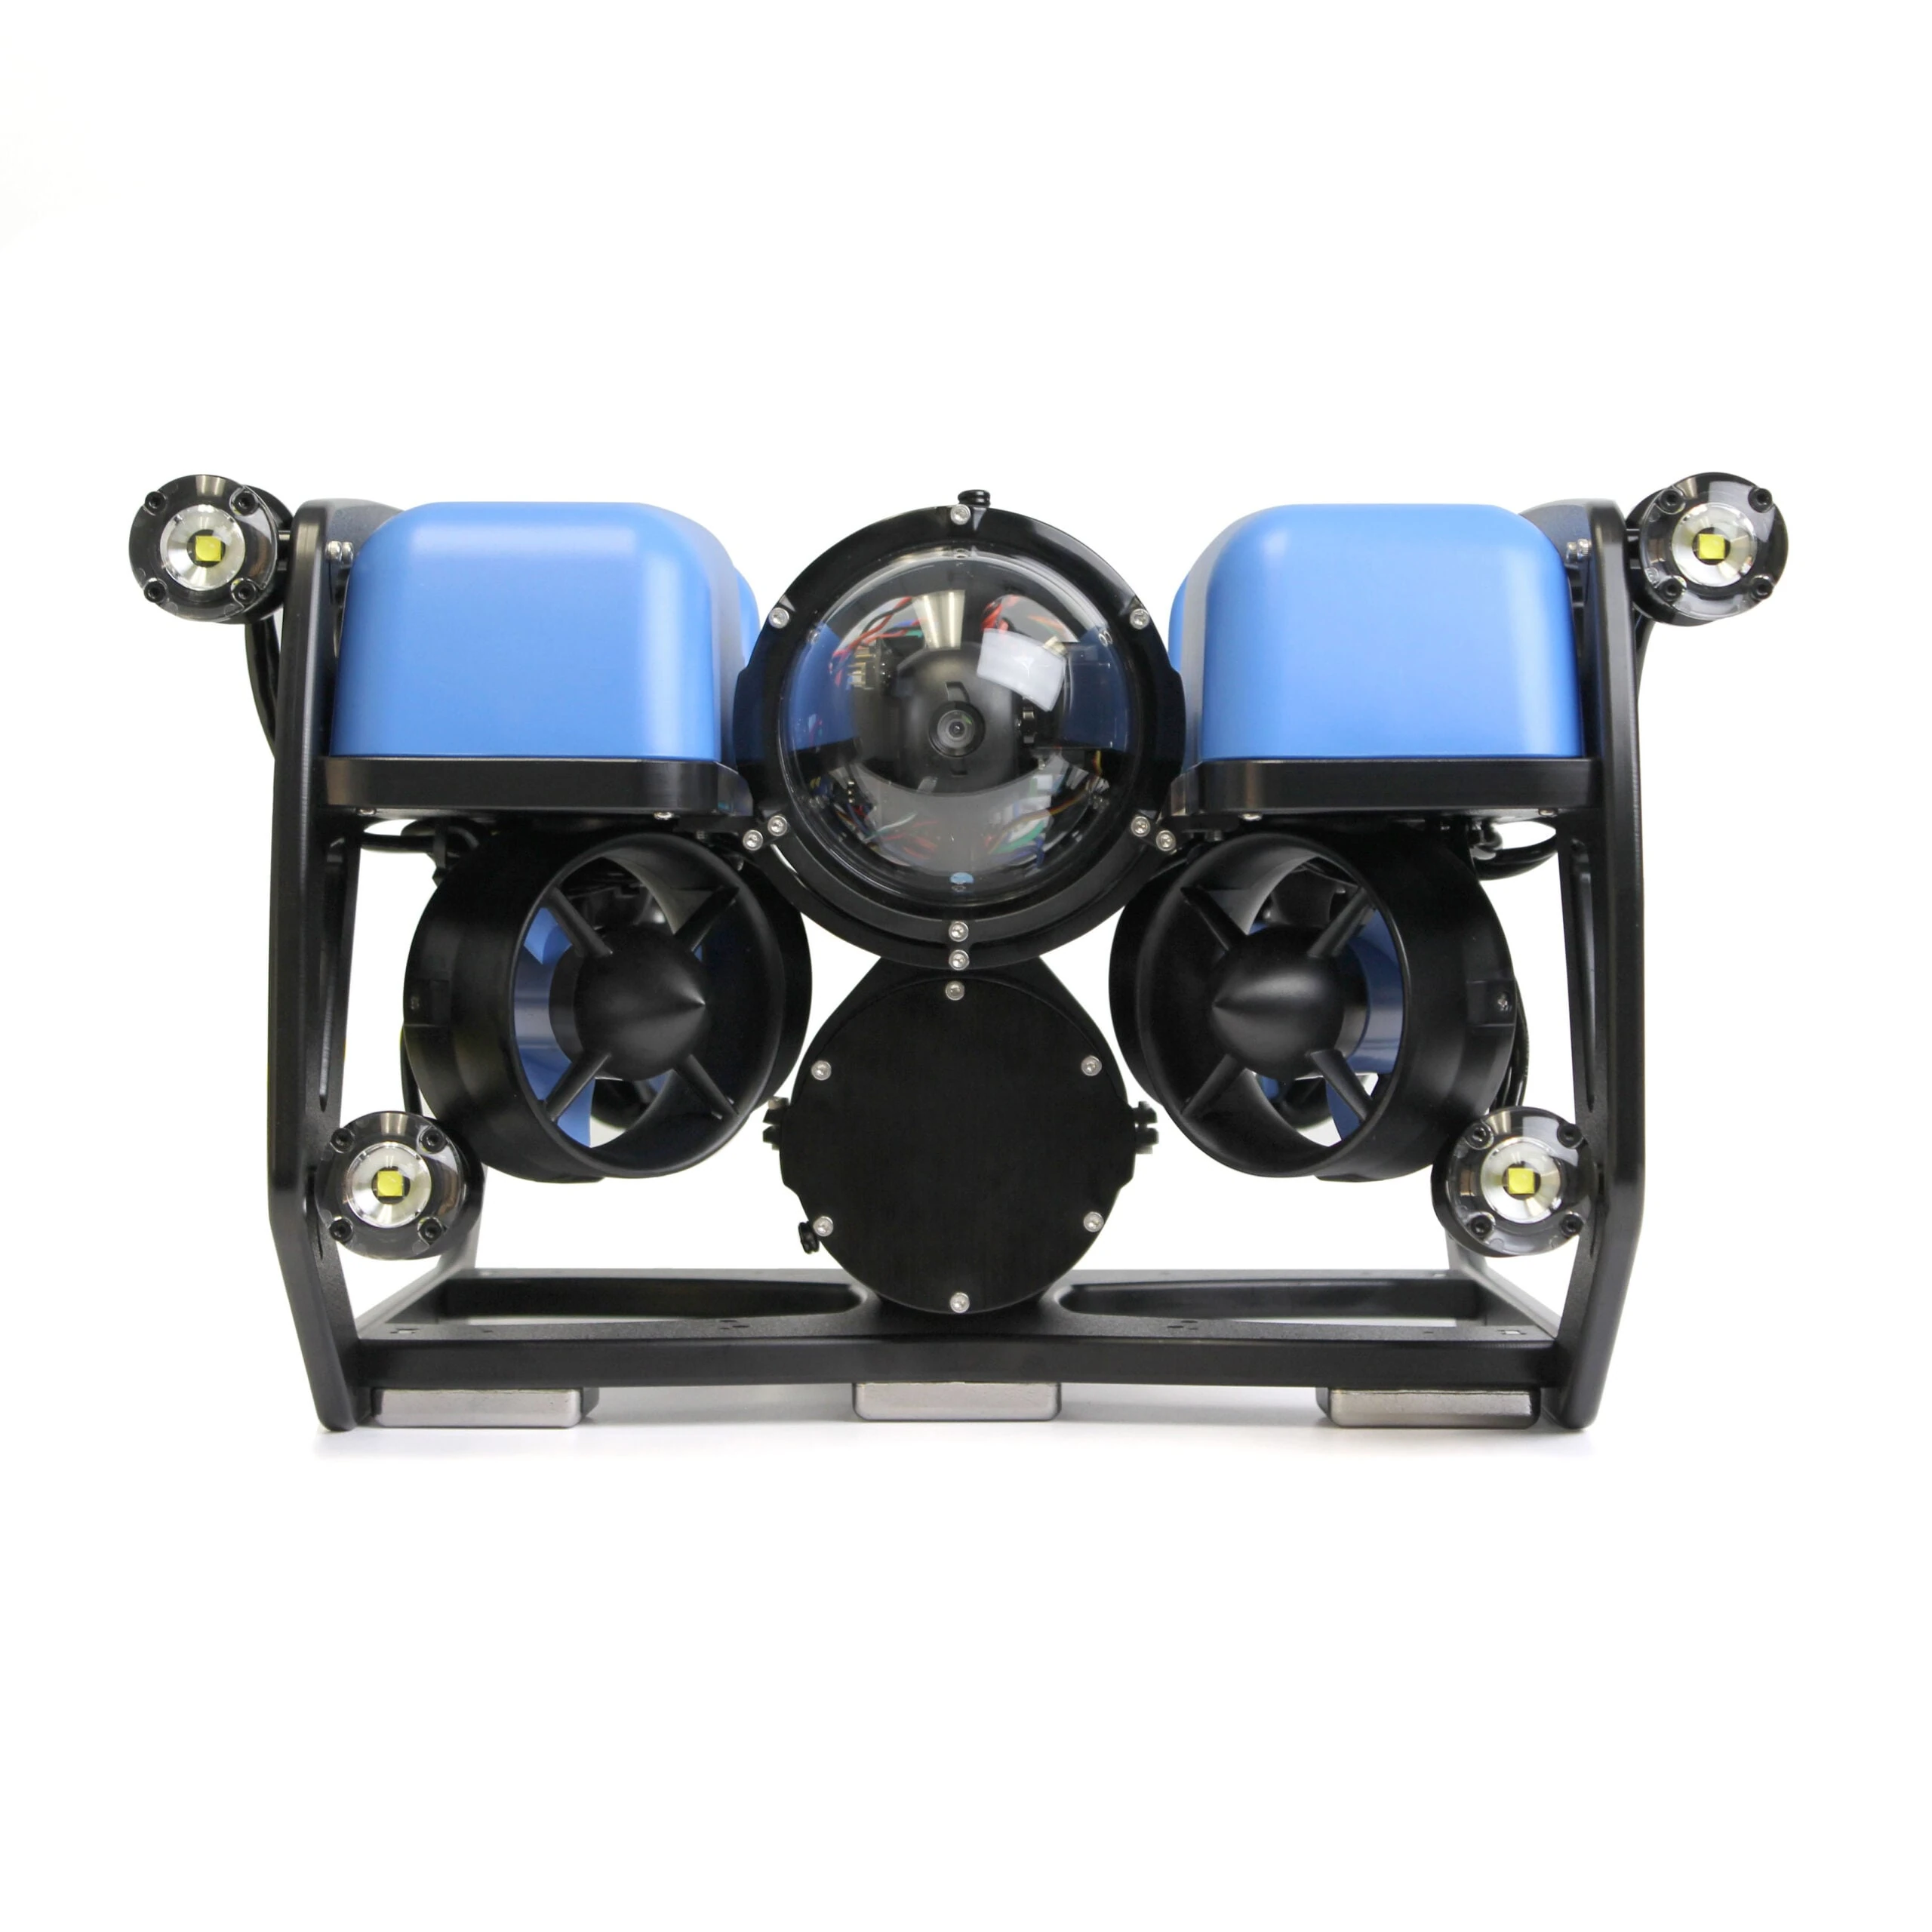
Explore DJI, Autel and the wider robotics world. Find the Nexus catalogue profile or start an integration assessment for your aircraft, ground robot or marine vehicle.
The 38 aircraft entries below are from the supplied HelloGeo Nexus catalogue: nine DJI RC, 24 Autel-family profiles (including two DragonFish VTOL) and five Dock aircraft. They describe planning and integration scope, not independent field qualification of every model.
02 / Integration assessment
Open the conversation.
Other manufacturers are reference platforms for an assessment. Their appearance here does not imply a partnership, approved integration or universal HelloGeo control. We scope the interfaces and acceptance criteria with you.
An enterprise aircraft platform with a separate Nexus catalogue profile. Payload choices and native operations require configuration-specific acceptance.
View 1 catalogue profile
Matrice 400
Confirm controller, firmware and payload. Cloud cold start is not established in the supplied Nexus scope.
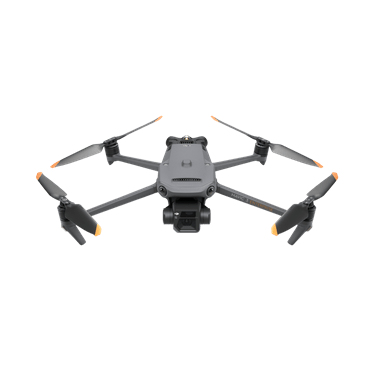
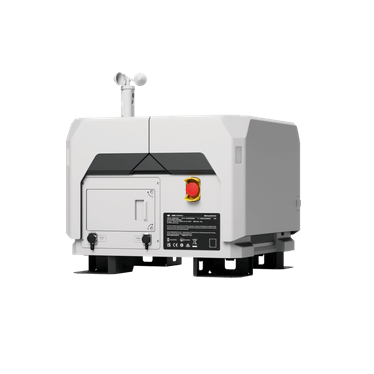
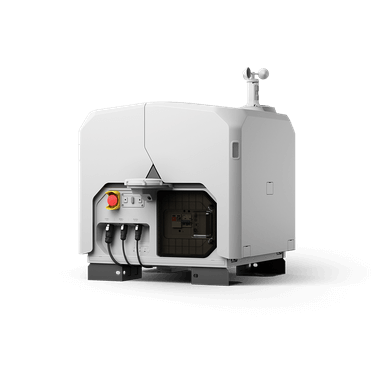
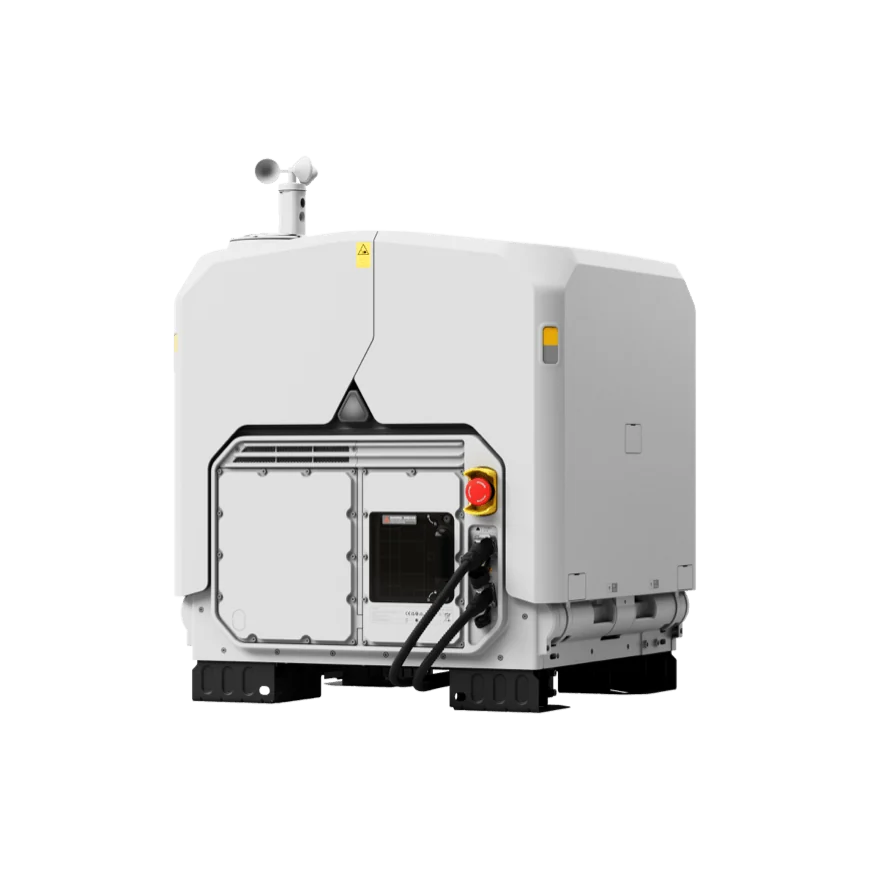
DJI Dock 4 pairs with Matrice 5TD and the required O4 Ground Station. Nexus includes a dedicated Cloud API 2 module for this configuration.
Aircraft & configuration
Matrice 5TD
Cloud API 2 configuration, discovery and operational workflow adapters. Licensed access, site commissioning and acceptance remain required.
Required configuration
DJI Dock 4 station
DJI Matrice 5TD aircraft
O4 Ground Station
Licensed DJI base and authorised organisation access
Dedicated Cloud API 2 configuration and commissioning workflows, with operation, recovery and history adapters. Device capabilities, licensed access and site acceptance govern availability; operational controls remain commissioning-gated.
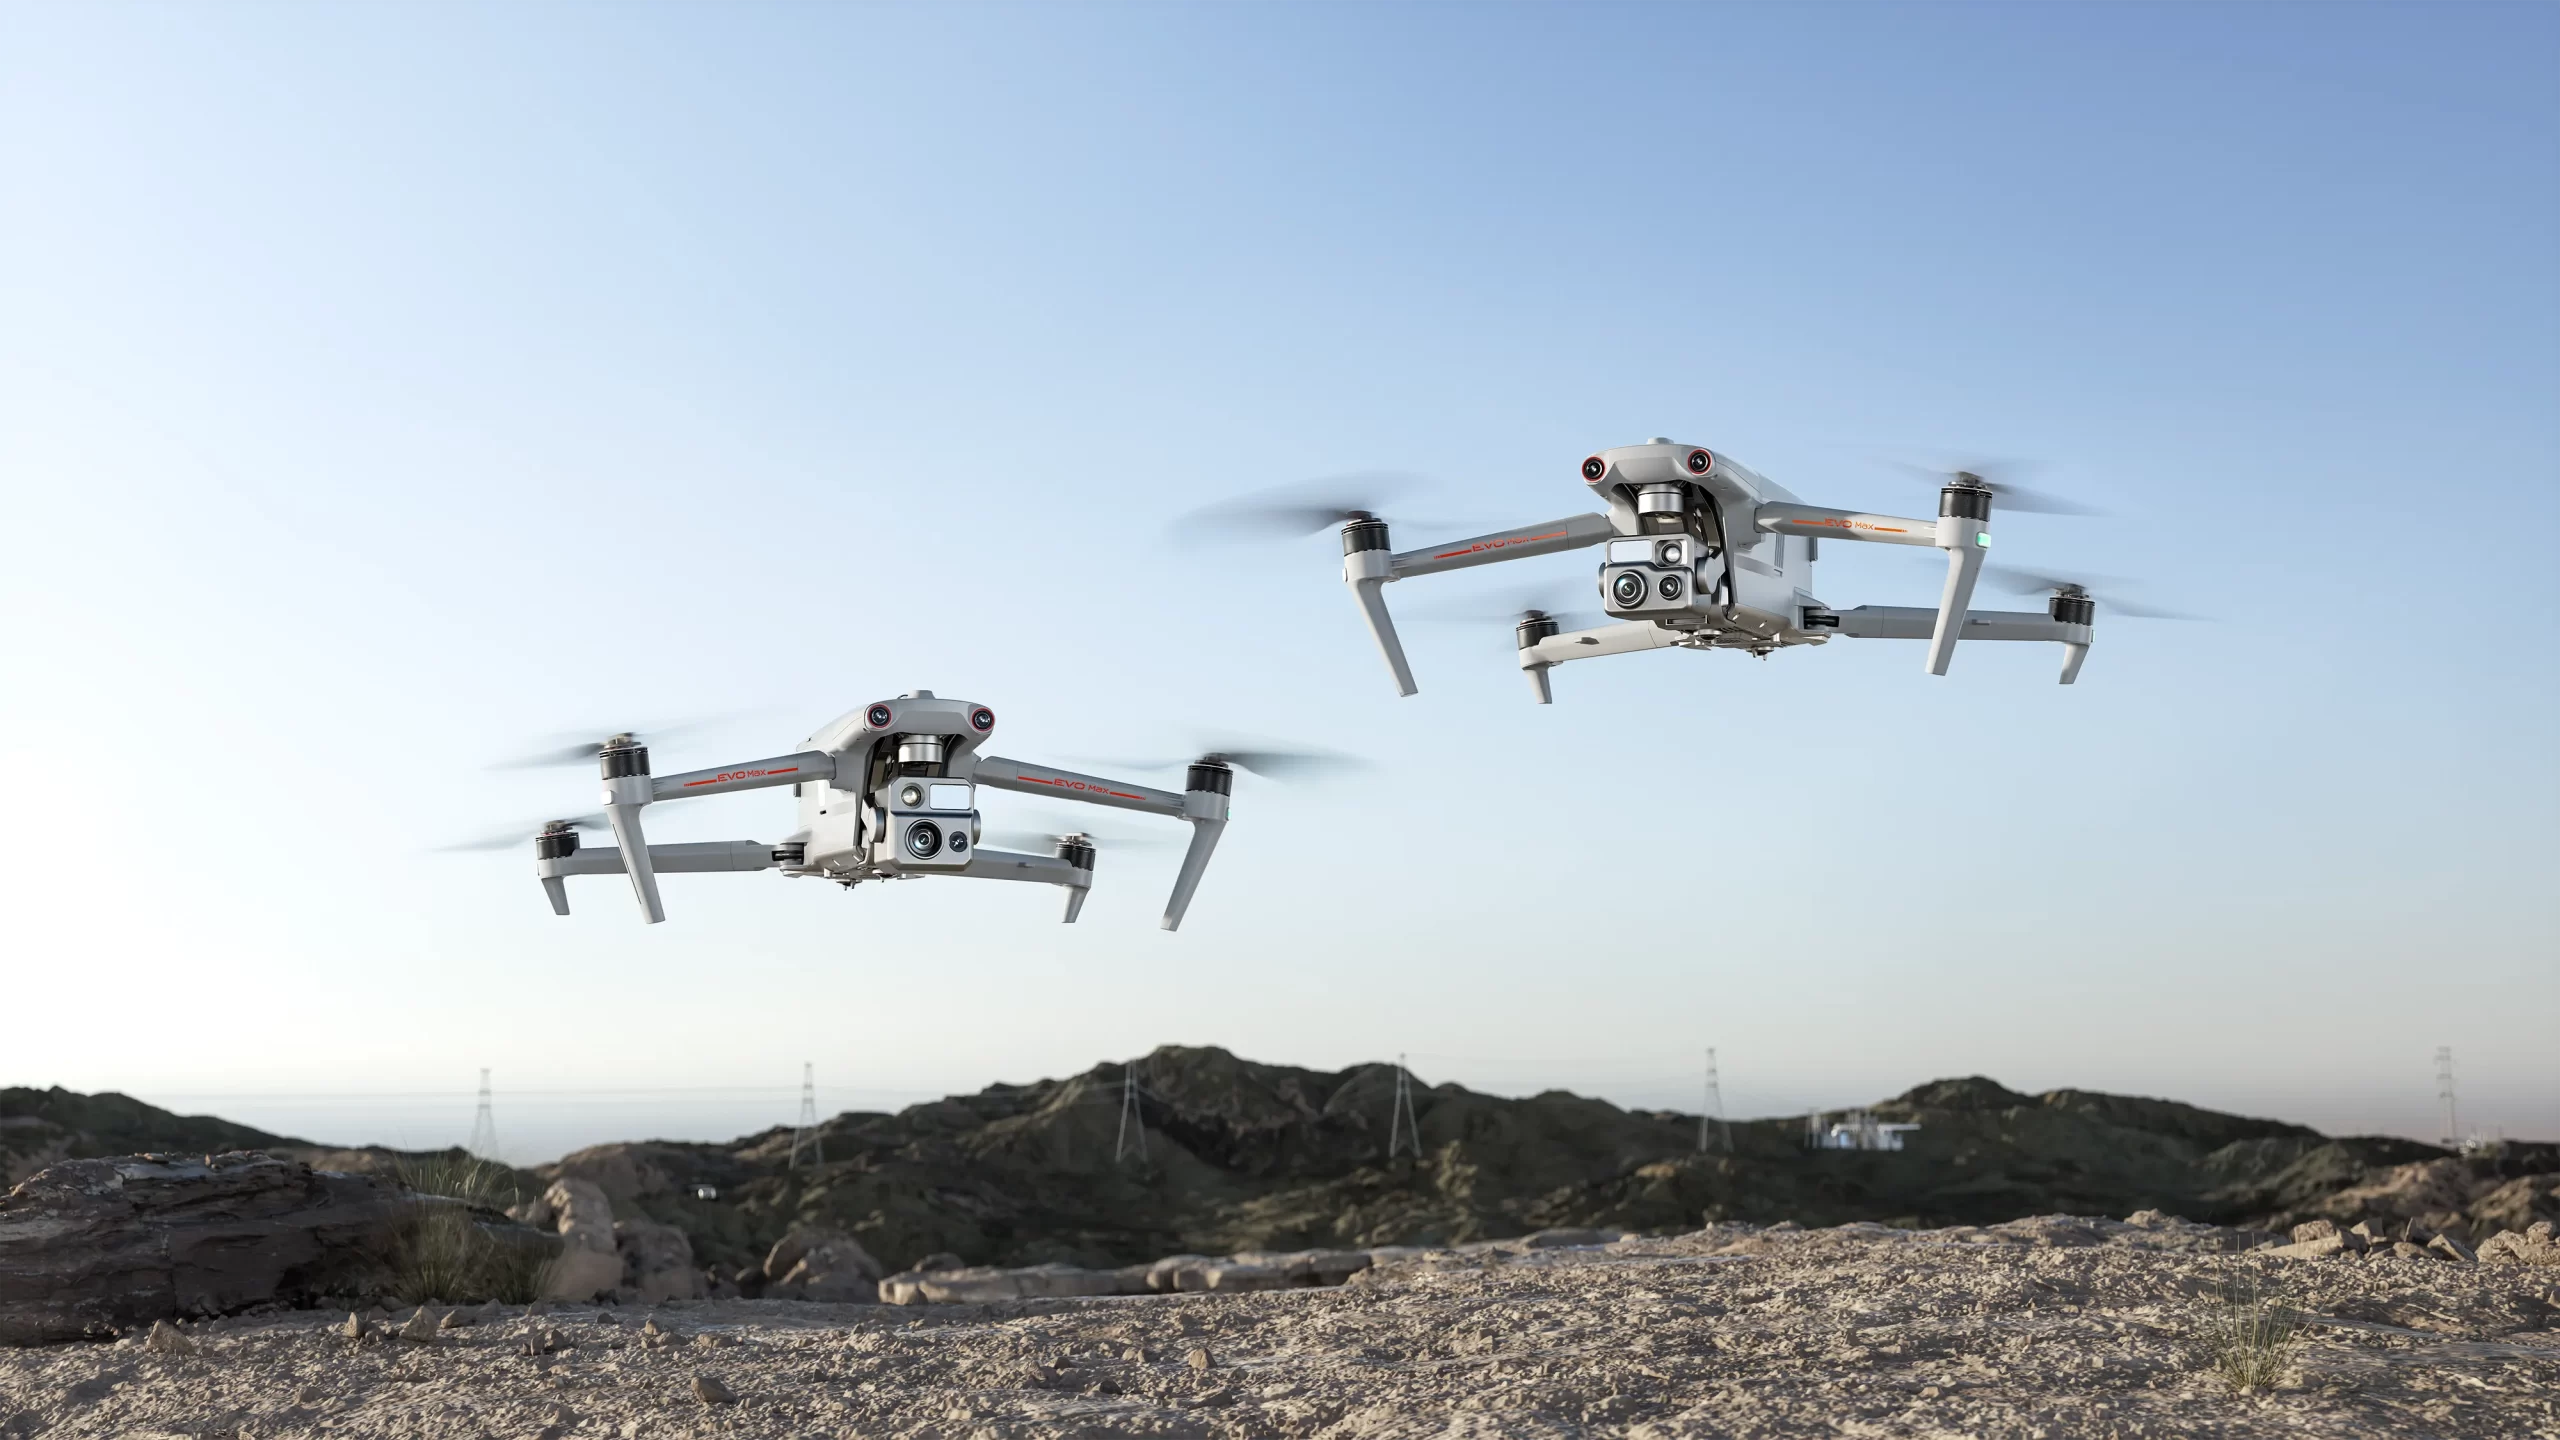
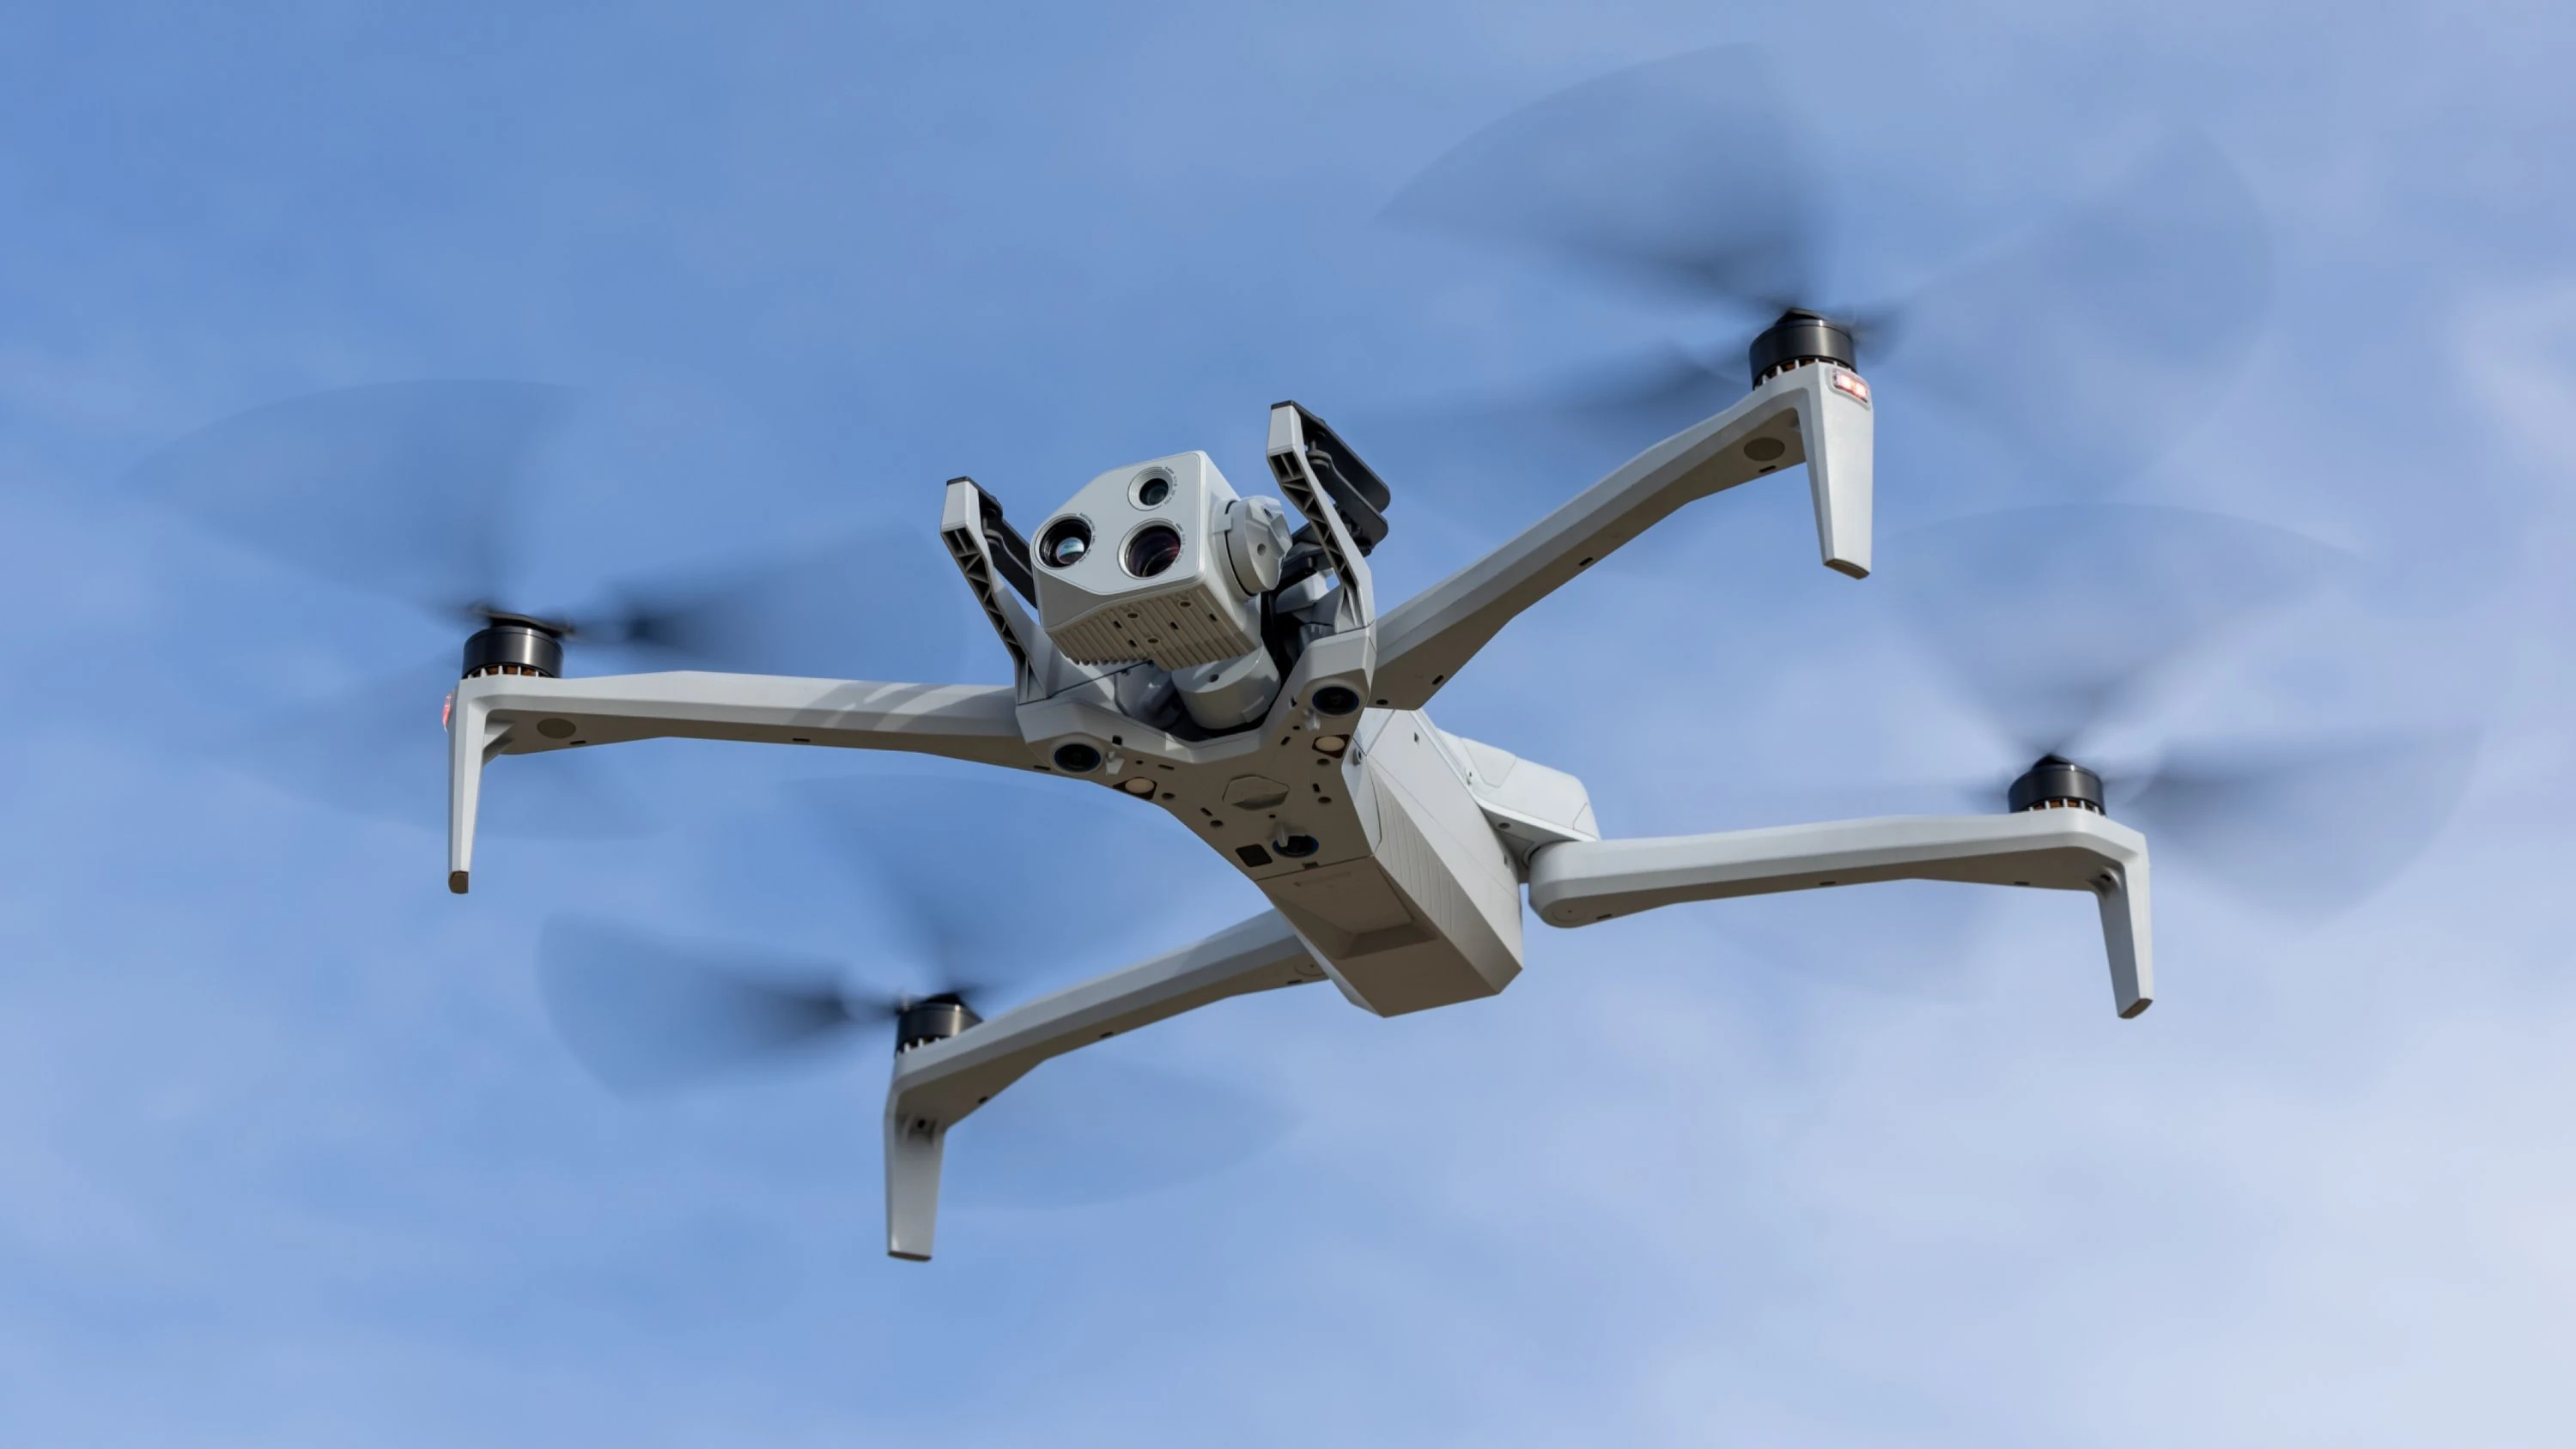
EVO Max, EVO Lite Enterprise, Alpha and other labels retained from the supplied Nexus brochure. The image shows the EVO Max family only.
View 9 catalogue profiles
EVO Max 4T
EVO Max 4N
EVO Max 4T Pro
EVO Lite 6K Enterprise
EVO Lite 640T Enterprise
Autel Alpha
Autel Titan
EVO III
EVO III Enterprise
Autel currently lists an EVO III Series. Titan, EVO III Enterprise and exact Max 4T Pro catalogue labels still need manufacturer confirmation. Catalogue inclusion is not a release or qualification claim.
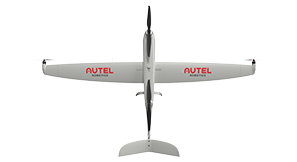
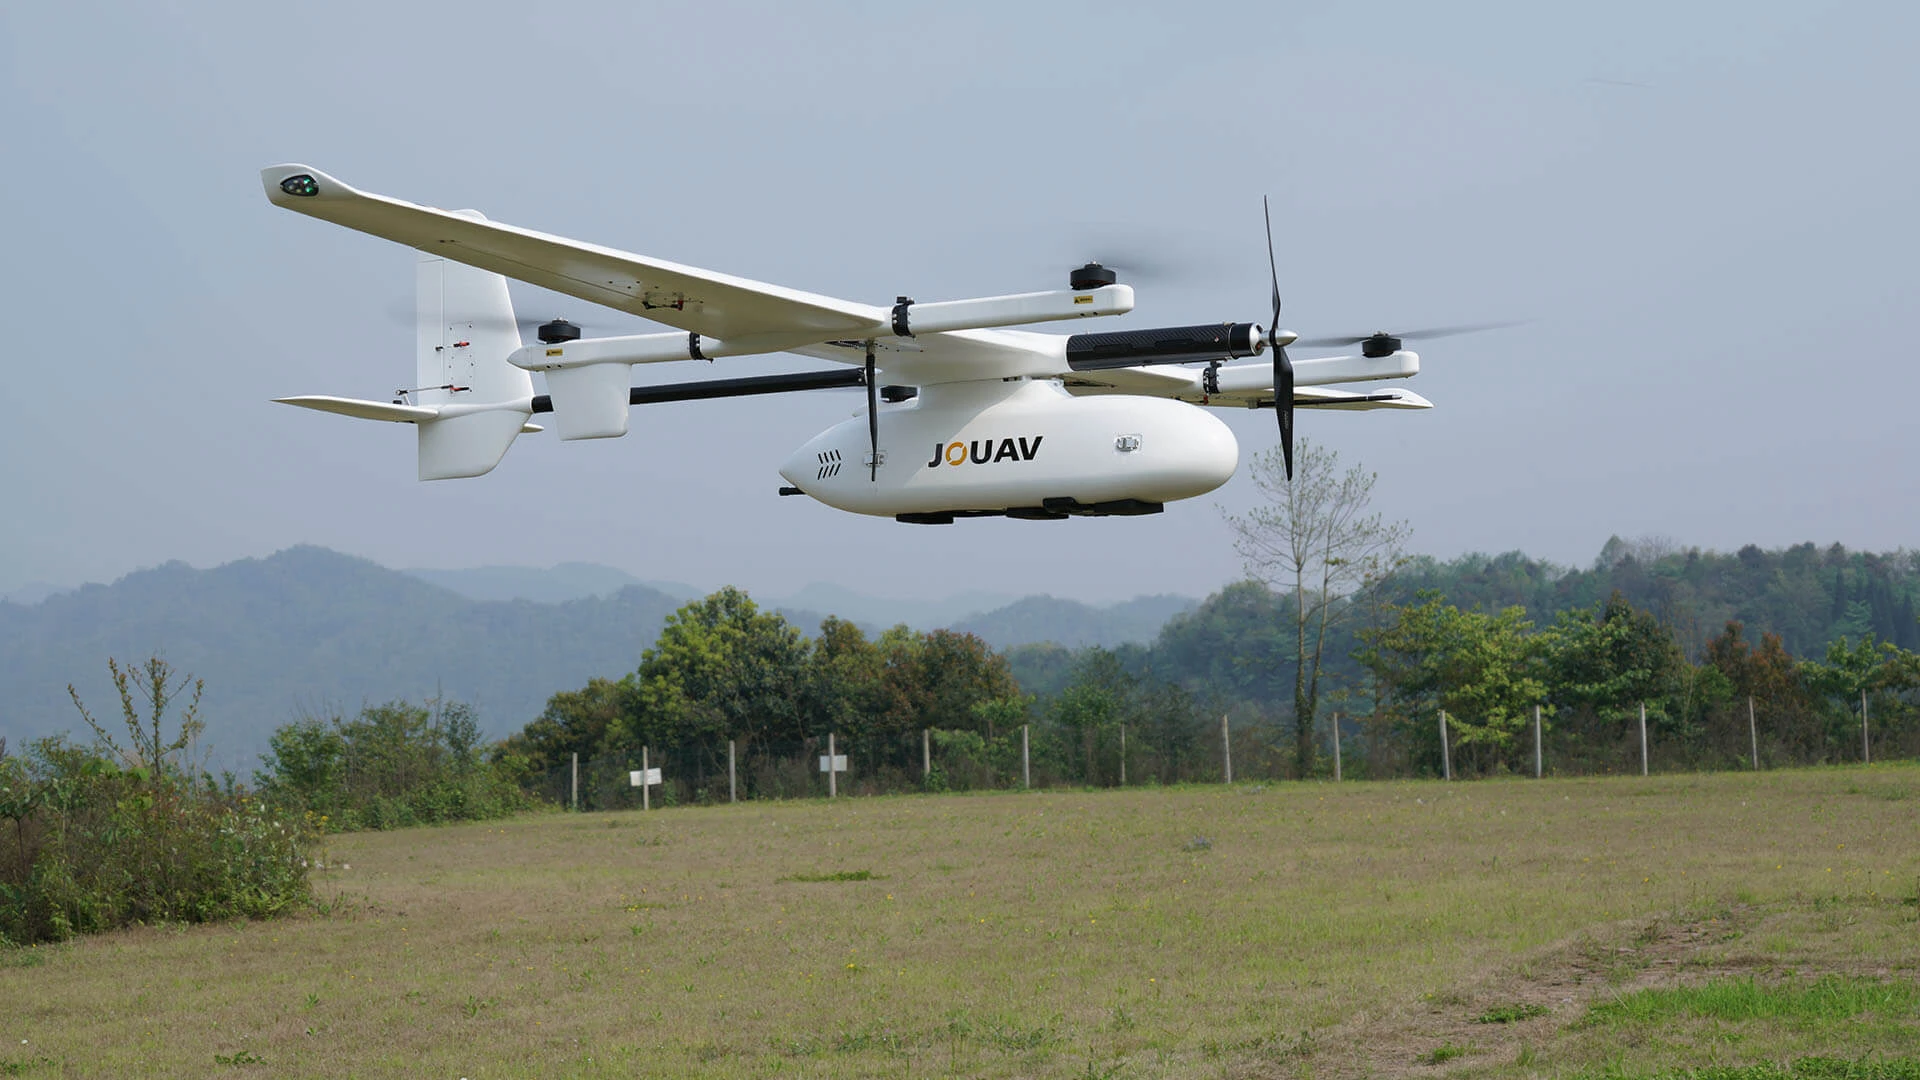
A tilt-rotor VTOL family for longer-area missions. Nexus source material describes waypoint/grid planning, footprint, overlap and JSON/GeoJSON geometry.
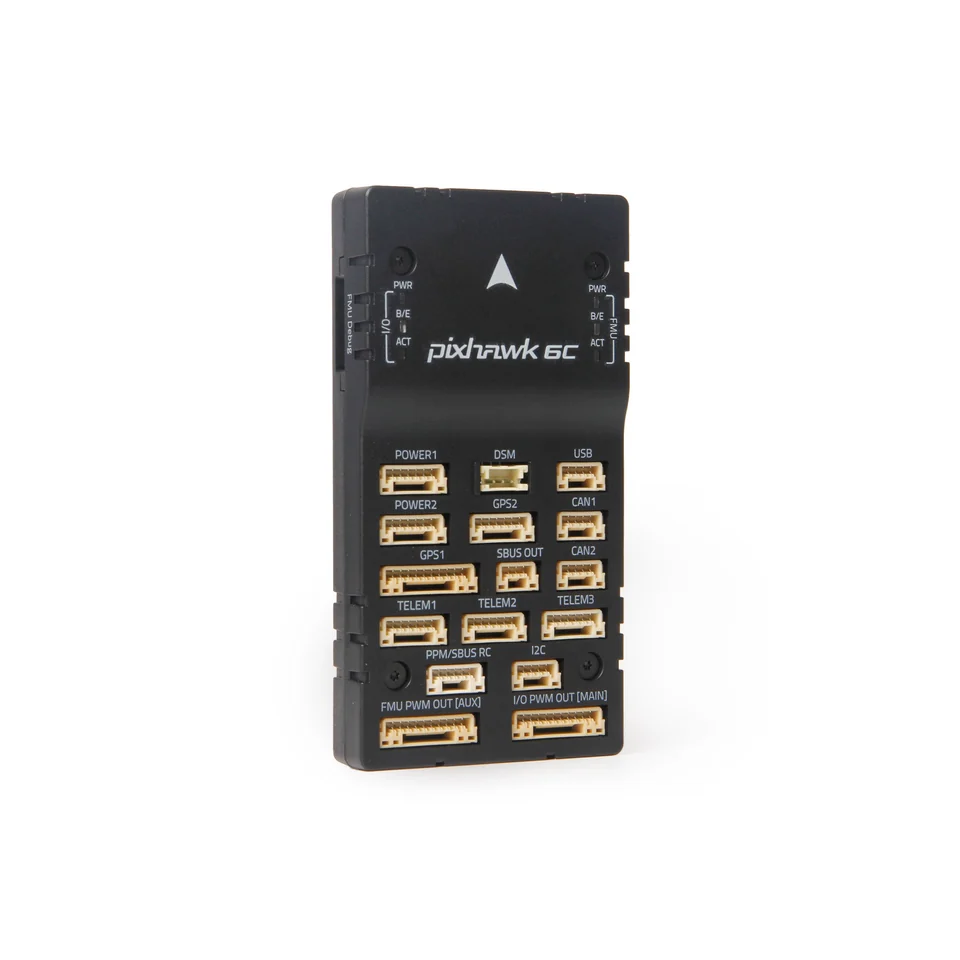
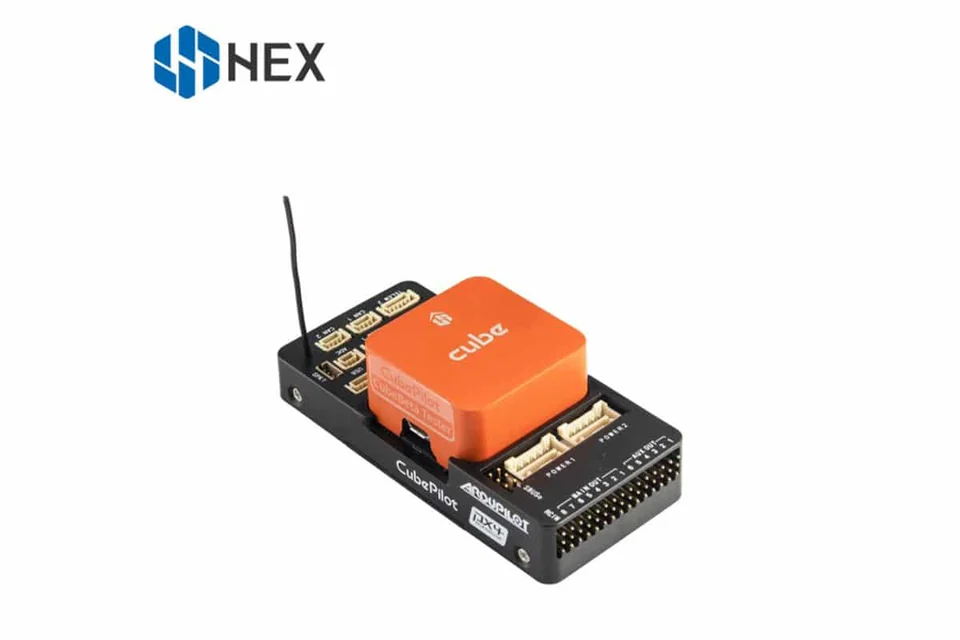
HelloGeo Flight is the separate ground-control application described for MAVLink-based ArduPilot/PX4 workflows. Pixhawk identifies flight-controller hardware, not an aircraft model.
Models & assessment
Pixhawk-based configurations
ArduPilot
PX4
MAVLink
Protocol availability alone does not qualify an aircraft. Review firmware, message support, vehicle type and every requested function.
Enterprise multirotor reference for visual and thermal inspection. Assessment starts with the manufacturer interfaces and the outputs your project needs.
Models & assessment
X10
Review permitted developer access, data exports, sensor metadata and operational boundaries. HelloGeo integration is not established.
Industrial multirotor reference with an established manufacturer documentation ecosystem. Exact aircraft generation and payload remain part of the assessment.
Models & assessment
Astro
Astro Max
HelloGeo integration is not established. Confirm the aircraft, controller, firmware, payload and SDK together before deployment.
Define the jobSurvey, inspection, asset inventory or marine data.
Identify the configurationModel, controller, firmware, payload and connection.
Choose the data pathPermitted SDK/API, imagery, telemetry or file exchange.
Validate the deploymentAgree bench checks, field acceptance and support scope.
CONNECTED WITH NEXUS
Match the platform to the plan.
Nexus brings structure planning, mission libraries and operational review together. Available route types and native execution differ by aircraft family.
01 / NEXUS
Structure planning
Single-façade, four-sided building and circular waypoint planning, with route parameters kept visible for review.
No. The supplied Nexus catalogue names nine DJI RC profiles plus five aircraft in Dock 2/3/4 pathways. Other DJI consumer, delivery or agriculture models require a separate assessment. Native functions depend on the exact aircraft, controller, firmware, payload and supported SDK.
Can a new OEM or ground robot join my workflow?
Start with a compatibility assessment. Some projects need file or imagery exchange; others need a permitted SDK/API, a gateway or custom integration. We agree the requested functions and evidence before describing a configuration as qualified.
How are Pixhawk, PX4 and ArduPilot different?
Pixhawk refers to flight-controller hardware. PX4 and ArduPilot are autopilot software ecosystems. MAVLink is a communications protocol. HelloGeo Flight’s documented pathway is distinct from the DJI and Autel controller integrations.
Surface GPS can establish a reference, but submerged vehicles require appropriate underwater positioning or navigation inputs. Define how sonar, video, depth and position are synchronized before selecting the marine workflow.
Manufacturer names, trademarks and product imagery belong to their respective owners. Product references do not imply a HelloGeo partnership or qualification of every configuration.
 Nexus catalogue profile